ROVINA
summary
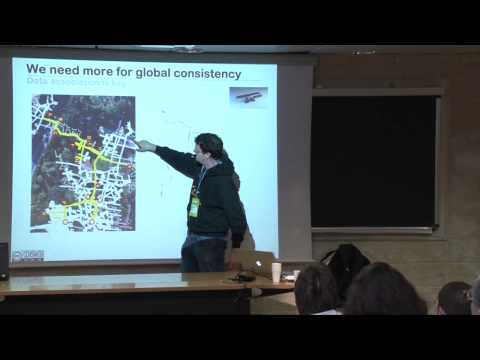
A three‑and‑a‑half year EU research project builds a tracked robot platform outfitted with spinning LiDAR, Kinect‑style depth cameras, a multi‑camera array and IMU to autonomously explore catacombs, register point clouds with a new real‑time algorithm, optimize global maps to centimeter accuracy and produce photorealistic textured reconstructions using learned BRDFs. The consortium reports 3.6 million Euros budget, sensors streaming two terabytes per hour and a robot with seven hours autonomy that successfully navigates stairs, debris and long dark tunnels.
AI-written summary · about
chapters (8)
- 0:00Start
- 15:36Point Cloud Reconstruction
- 19:33Obtain consistency with optimization
- 21:02Structure from motion
- 23:19Learning materials
- 24:20Removing light effects
- 25:22Example 1: Learning reflectance
- 26:50Example 2: Learning Reflectance
related talks
 42mAdvancing underwater exploration with robotics
 26mFrom Panoramic Vision to Lightweight 3D Worlds for Semantic Visual Tracking
 16m"Putting a New Spin on
 33mReducing the environmental impact of agriculture with robotics
 10mRyan Luke Johns Co-founder & CEO, Gravis Robotics | Slush 2025
 48mROS on your robot: the tale of an inside, an outside robot and 2 arms
 55mUsing a Lidar for Robot Navigation in a Room
 26mAI for Autonomous mobile robots