AI for Autonomous mobile robots
summary
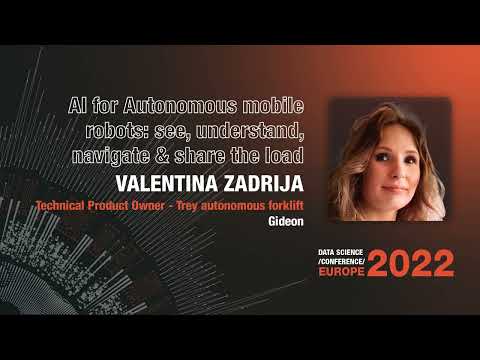
Company builds a working tray autonomous forklift that unloads trailers using vision only, no GPS, running semantic and instance segmentation, on-camera stereo depth and visual SLAM. Models run on limited hardware, use Transformers for image-level matching, and are trained with self-supervision plus in-house data collection and annotation. A 3D map made on a sunny day still localizes a robot in rain, and the project involves roughly 70 people in the autonomous team.
AI-written summary · about
chapters (14)
- 0:00Autonomous mobile robots & AI
- 1:36Tray forklifts for autonomy
- 3:45AI-powered robotics stack
- 5:30Custom stereo cameras for vision
- 7:00Semantic segmentation in robots
- 8:472D images to 3D pose
- 10:16Depth estimation challenges
- 11:41Visual localization without GPS
- 14:30Neural networks for localization
- 16:39Training data for localization
- 17:43Dynamic environments & seasons
- 19:08Mapping under rain demo
- 20:37Team behind the tech
- 21:18Q&A on data & adaptability
related talks
 06mAI in production: The droids you’re looking for
 24mAI in maritime - Autonomous ships
 04mAI and the Robotics Revolution
 26mAutonomy – The Era of Vehicles Without Drivers
 41mAI applications in autonomous driving
 31mDeep learning for self-driving vehicle technology
 26mAutoware Introduction
 26mFrom Panoramic Vision to Lightweight 3D Worlds for Semantic Visual Tracking