Enforcing Constraints for Time Series Prediction in Supervised/Unsupervised/Reinforcement Learning

summary
A pipeline enforces dynamical constraints to learn discrete flow maps from time series using three modes of learning and continual updates, demonstrated on the Lorenz system. Supervised models add a velocity-matching loss with annealing to train on 0–3s then predict to 9s with a larger Δt and retain attractor behavior. GANs augment the discriminator with residuals and a trainable correction term μ so convergence occurs by ~10k versus ~70k iterations without constraints. Actor‑critic uses a homotopy of the action‑value function to stabilize training, and periodic retraining on small chunks recovers lobe transitions missed by one‑time training.
AI-written summary · about
chapters (8)
- 0:00Introduction and motivation
- 1:06Problem setup and flow map learning
- 5:00Supervised learning with constraints
- 12:09Unsupervised learning with GANs
- 15:50Dynamical constraints in unsupervised learning
- 23:27Reinforcement learning approach
- 28:45Continual learning for time series
- 30:52Future directions and Q&A
related talks
 42mReinforcement Learning using Generative Models for Continuous State and Action Space Systems
 34mOffline Reinforcement Learning and Model-Based Optimization
 27mData-driven challenges in AI: scale, information selection, and safety
 49mUsing Deep Learning for Perception in Autonomous Systems: A Perspective from Control Theory
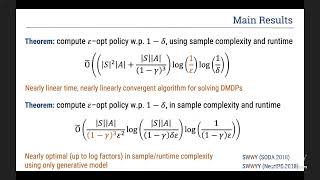 11mData Efficient Methods for Reinforcement Learning
 31mAdvanced machine learning time series....
 23mFLUX, Open Research, and the Future of Visual AI
 14mHuman-in-the-Loop Reinforcement Learning