Robotics and Sensors Using Erlang
summary
Claim: Erlang runs on bare metal to control robots and sensors using the GRiSP stack and a reduced BEAM/OTP runtime. The build uses an ARM Cortex‑M7 board with ~64 MB SDRAM, microSD boot, Pmods for sensors and motor drivers, static C drivers linked via rebar3 plugins, and Wi‑Fi (which cost a one‑year delay). A prototype fleet of about 50 nylon nodes and a wheeled robot demo that follows a person over Wi‑Fi demonstrate it actually works.
AI-written summary · about
chapters (13)
- 0:00Robotics with Erlang
- 1:11ECU reflashing to Erlang
- 3:01Embedded hardware design
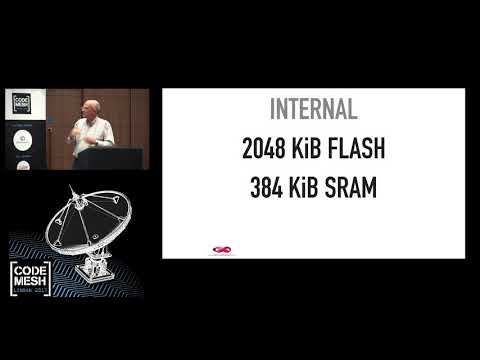
- 8:05Hardware specs
- 14:14Sensor interfaces
- 25:10Industrial transport prototype
- 26:38Pmods for sensors
- 29:10Live robotics demo
- 32:14Autumns software stack
- 38:56Deploying Erlang apps
- 40:09Live coding demo
- 44:18Future roadmap
- 47:10Q&A
related talks
 44mWireless Small Embedded Erlang Applications with Grisp
 39mErlang on Microcontrollers: The Research Continues
 36mFun with Rusty Robots
 39mReal-Time Rust in Robotics
 49mHow to Build an OS With Erlang: A Whistle-Stop Tour of HydrOS
 20m"Rust in Motion: Building Reliable and Performant Robotics Systems"
 02mRustbots - Robots powered by Rust
 30mEmbed it yourself