Developing Control for Mobile Robots

summary
A simple physics model of a two-motor planar drone produces three differential equations and initially shows inevitable fall in simulation (~15–17 s). Replacing open-loop control with a PID (then PD) controller stabilizes altitude and extends hover to about 35 s, including holding configurable heights (example: 2 m). A separate experiment trains a reinforcement-learning policy in simulation with state quantization to balance a cube; the learned policy keeps the cube near zero angle and improves with more training episodes.
AI-written summary · about
chapters (14)
- 0:00Robot control intro
- 1:01Stability classification
- 3:13Control system cycle
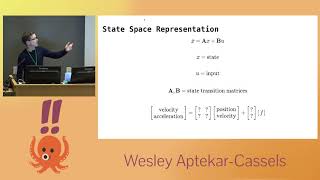
- 4:57Drone modeling
- 8:13Drone instability
- 11:02PID controller
- 13:56PID with drone
- 16:47Reinforcement learning
- 19:37Cube learning demo
- 21:26Q&A
- 23:23Analog control systems
- 26:15RL robot training
- 28:46Control search methods
- 30:10Conclusion
related talks
 10mRobots, rockets, and more! Control theory in 10 minutes!
 10mPyTorch in Robotics
 01h 35mDeep Robotic Learning
 49mUsing Deep Learning for Perception in Autonomous Systems: A Perspective from Control Theory
 01h 00m(Deep) Learning to Fly
 18mRobotics: why now?
 17mBeyond Automation: AI and the Evolution of Robotic Intelligence
 43mOn Kalman Filters and Robotics