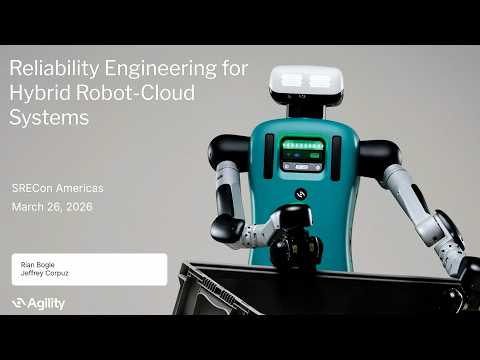
Reliability Engineering for Hybrid Robot-Cloud Systems
summary
Arc fleet management ties a cloud control plane to roaming robot nodes, handling intermittent MQTT sessions with QoS, defining robot SLOs and shaving MTTR via faster MTDD and alert correlation. Device platform runs K3S on read-only FS with GitOps, OCI images, OpenTelemetry and Fluent Bit for near-real-time observability, and uses Teleport for mTLS tunneling and auditable just-in-time access. Robots perform hours of continuous work; design assumes network partitions, prioritizes latency-sensitive notifications and over-the-air updates for configs, models and calibrations.
AI-written summary · about
chapters (7)
- 0:00Agility Robotics and hybrid systems
- 2:50Arc fleet management platform
- 4:55Network challenges for robot fleets
- 6:42SRE for unreliable edge networks
- 7:06Device management for robot ecosystems
- 10:39Device management system architecture
- 13:09Robots as edge devices
related talks
 33mFeeding the Cloud: Designing Data-Driven Robotics Systems
 43mPatterns for cloud-enabled robots
 25mBuilding a PaaS for Robotics with Kubernetes
 20m"Rust in Motion: Building Reliable and Performant Robotics Systems"
 27mDeterministic fleet management for autonomous mobile robots using Rust
 21mBuilding a PaaS for Robotics with Kubernetes
 22mKubernetes Robotics Edge Cluster System
 28mBuild smart robots and operate them easily with AWS Robotics